Kavin M. Govindarajan
Robotics PhD @ University of Michigan | NSF Graduate Research Fellow

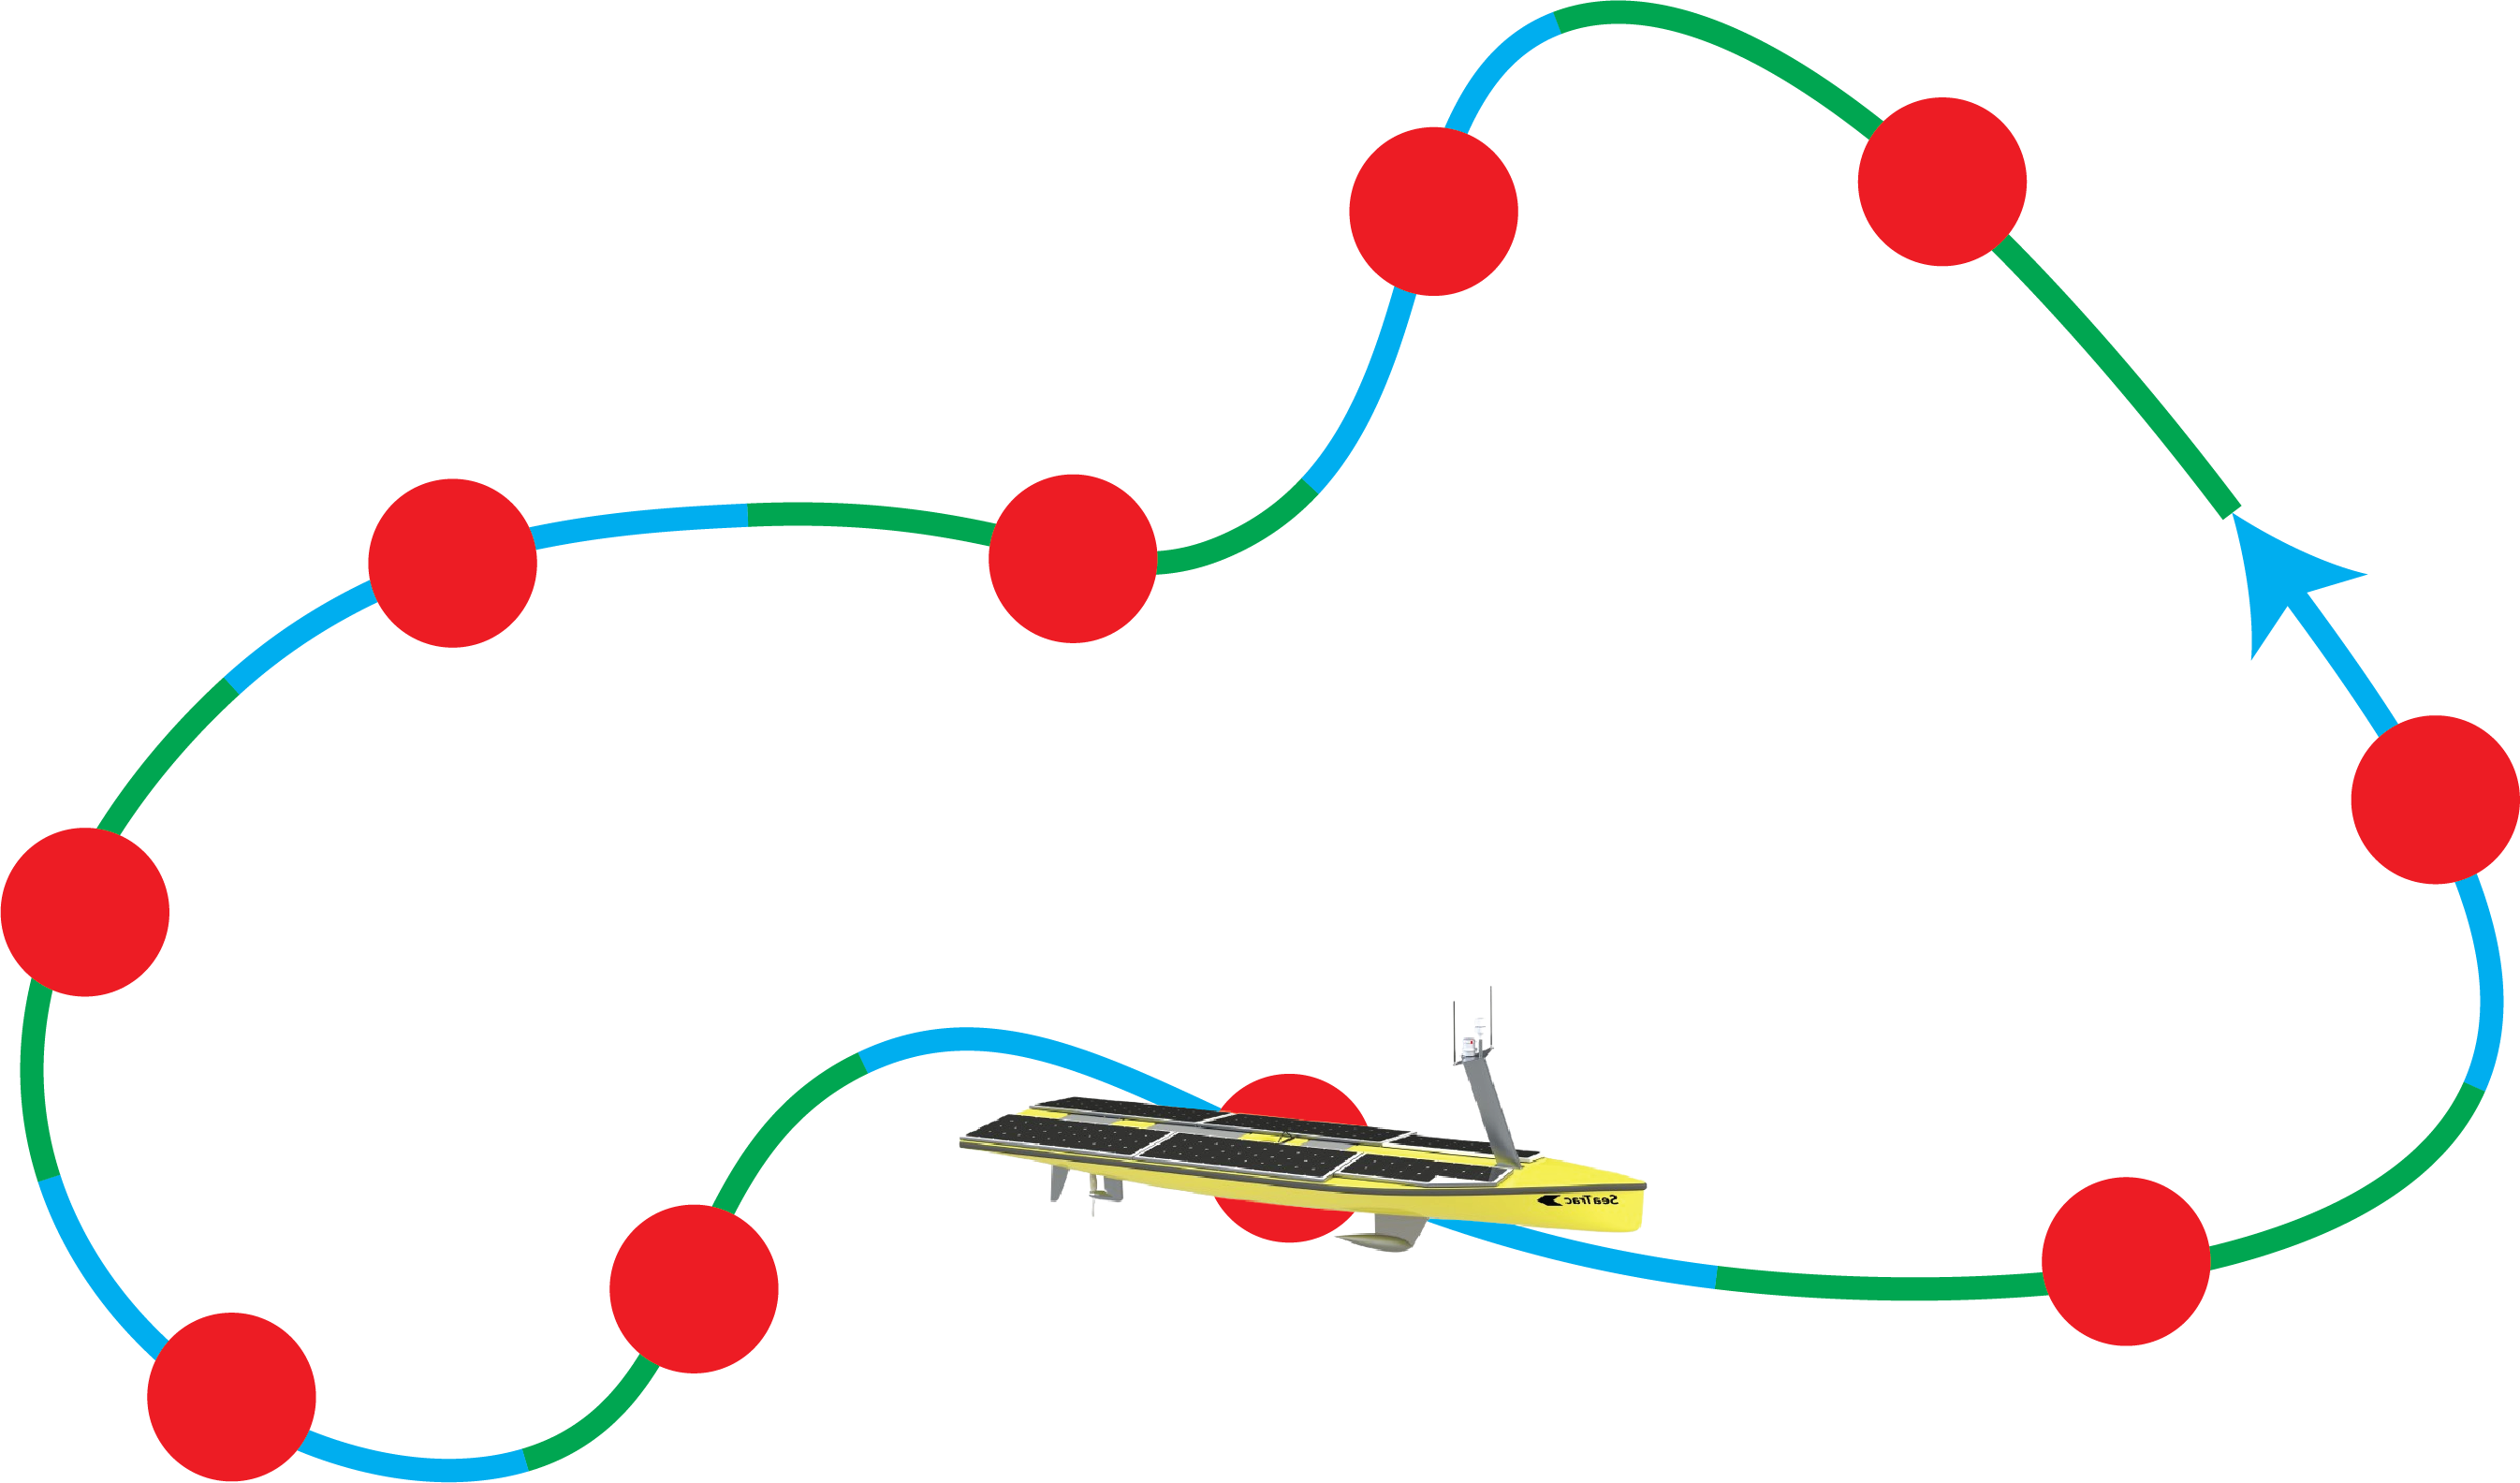
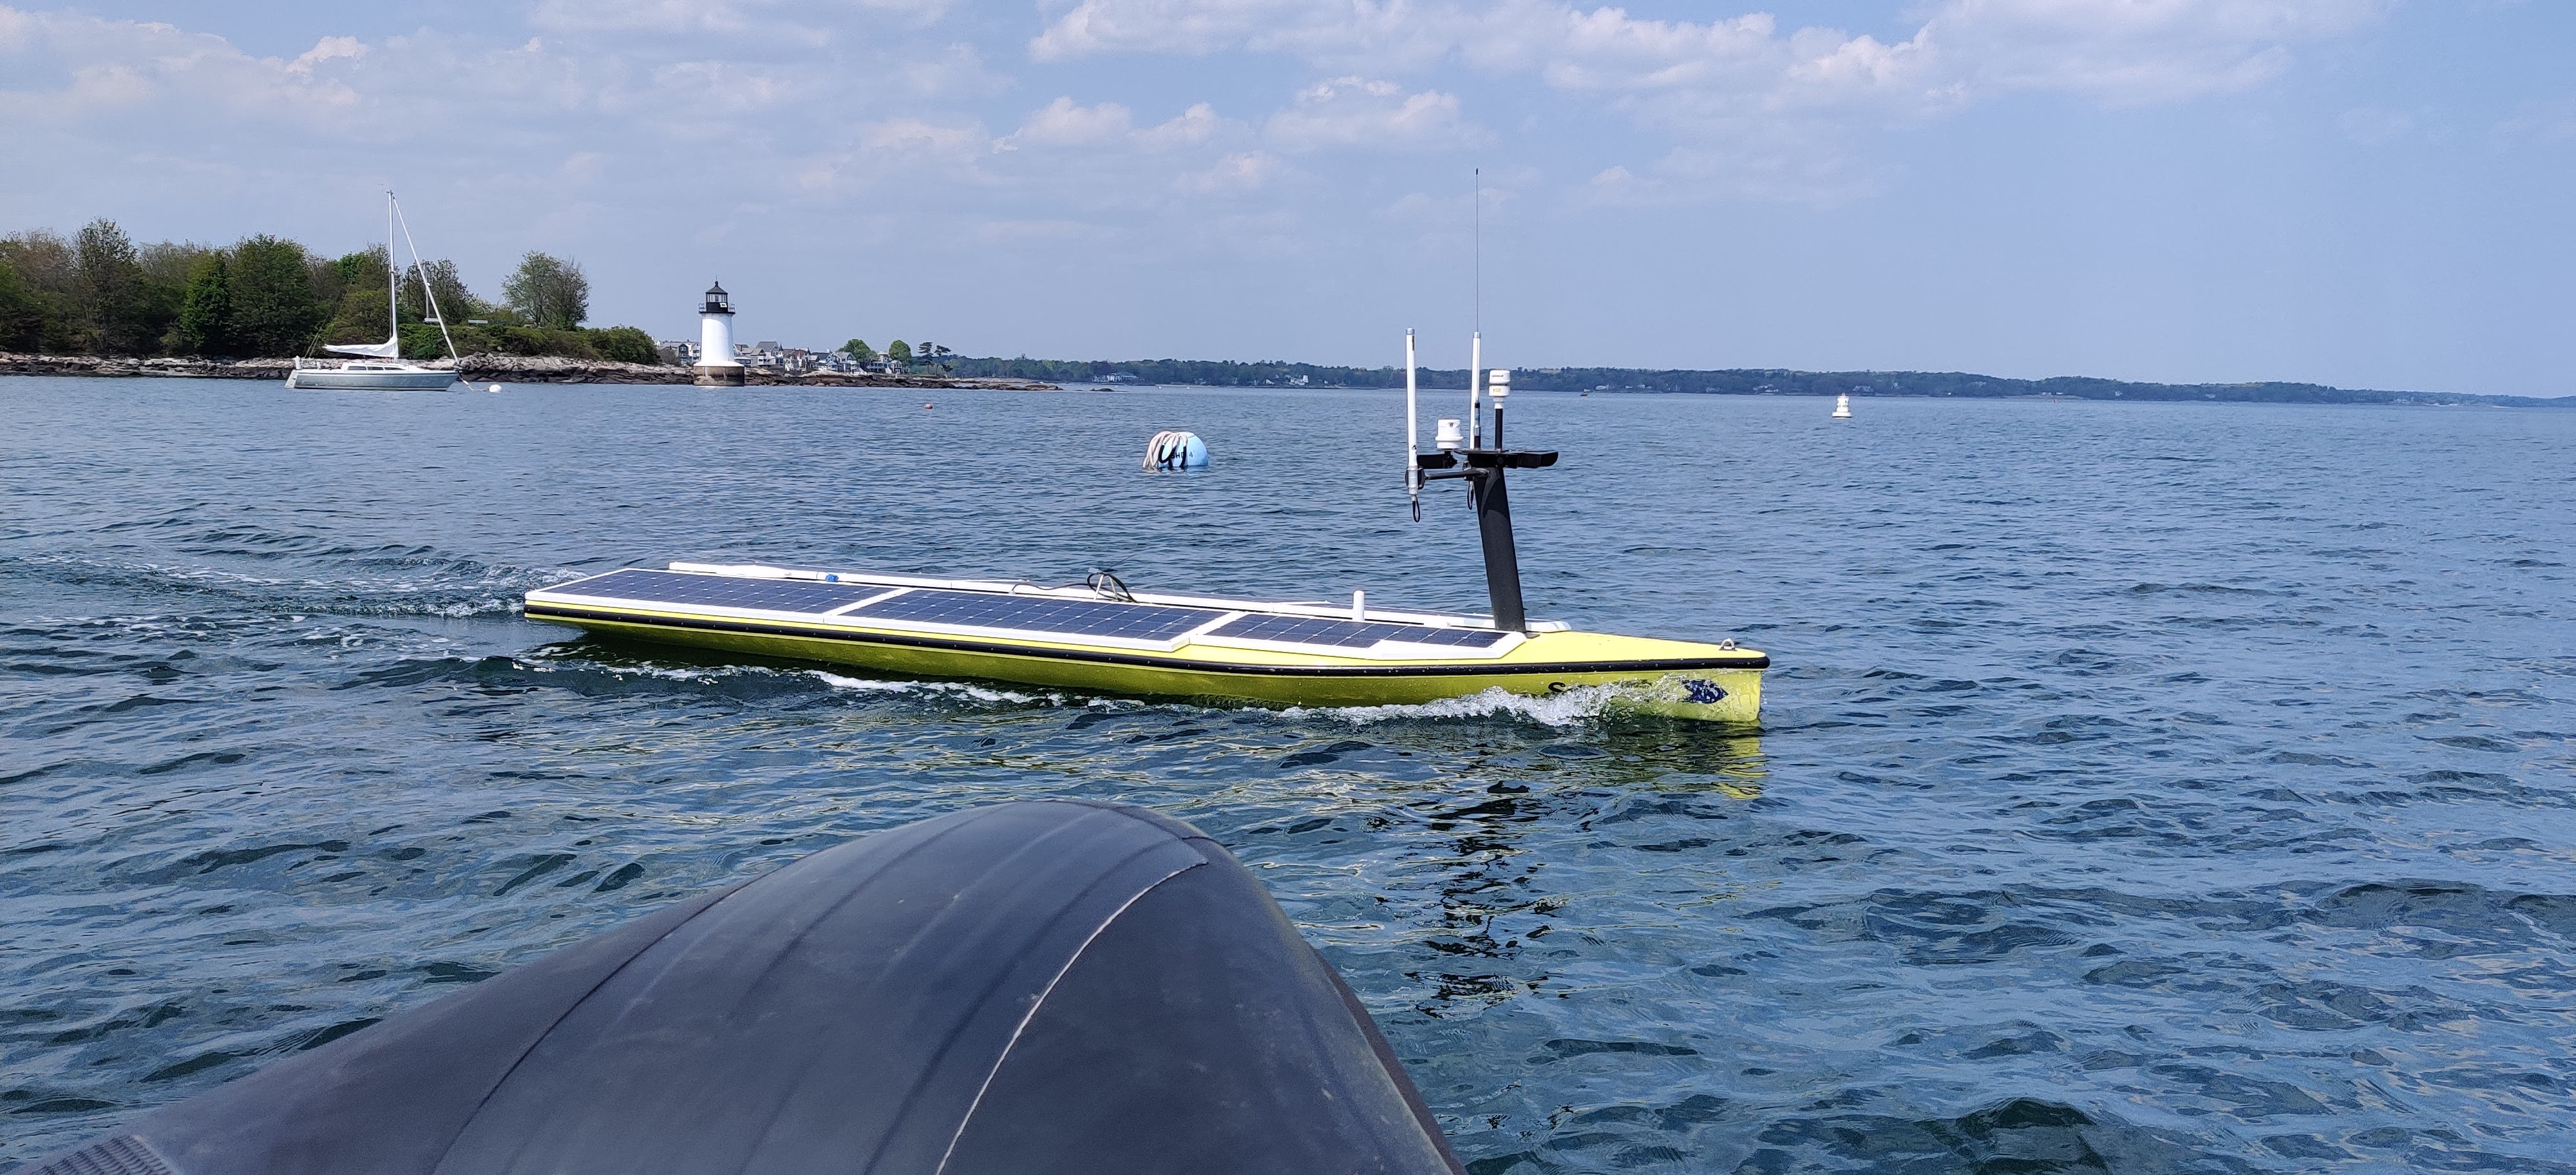
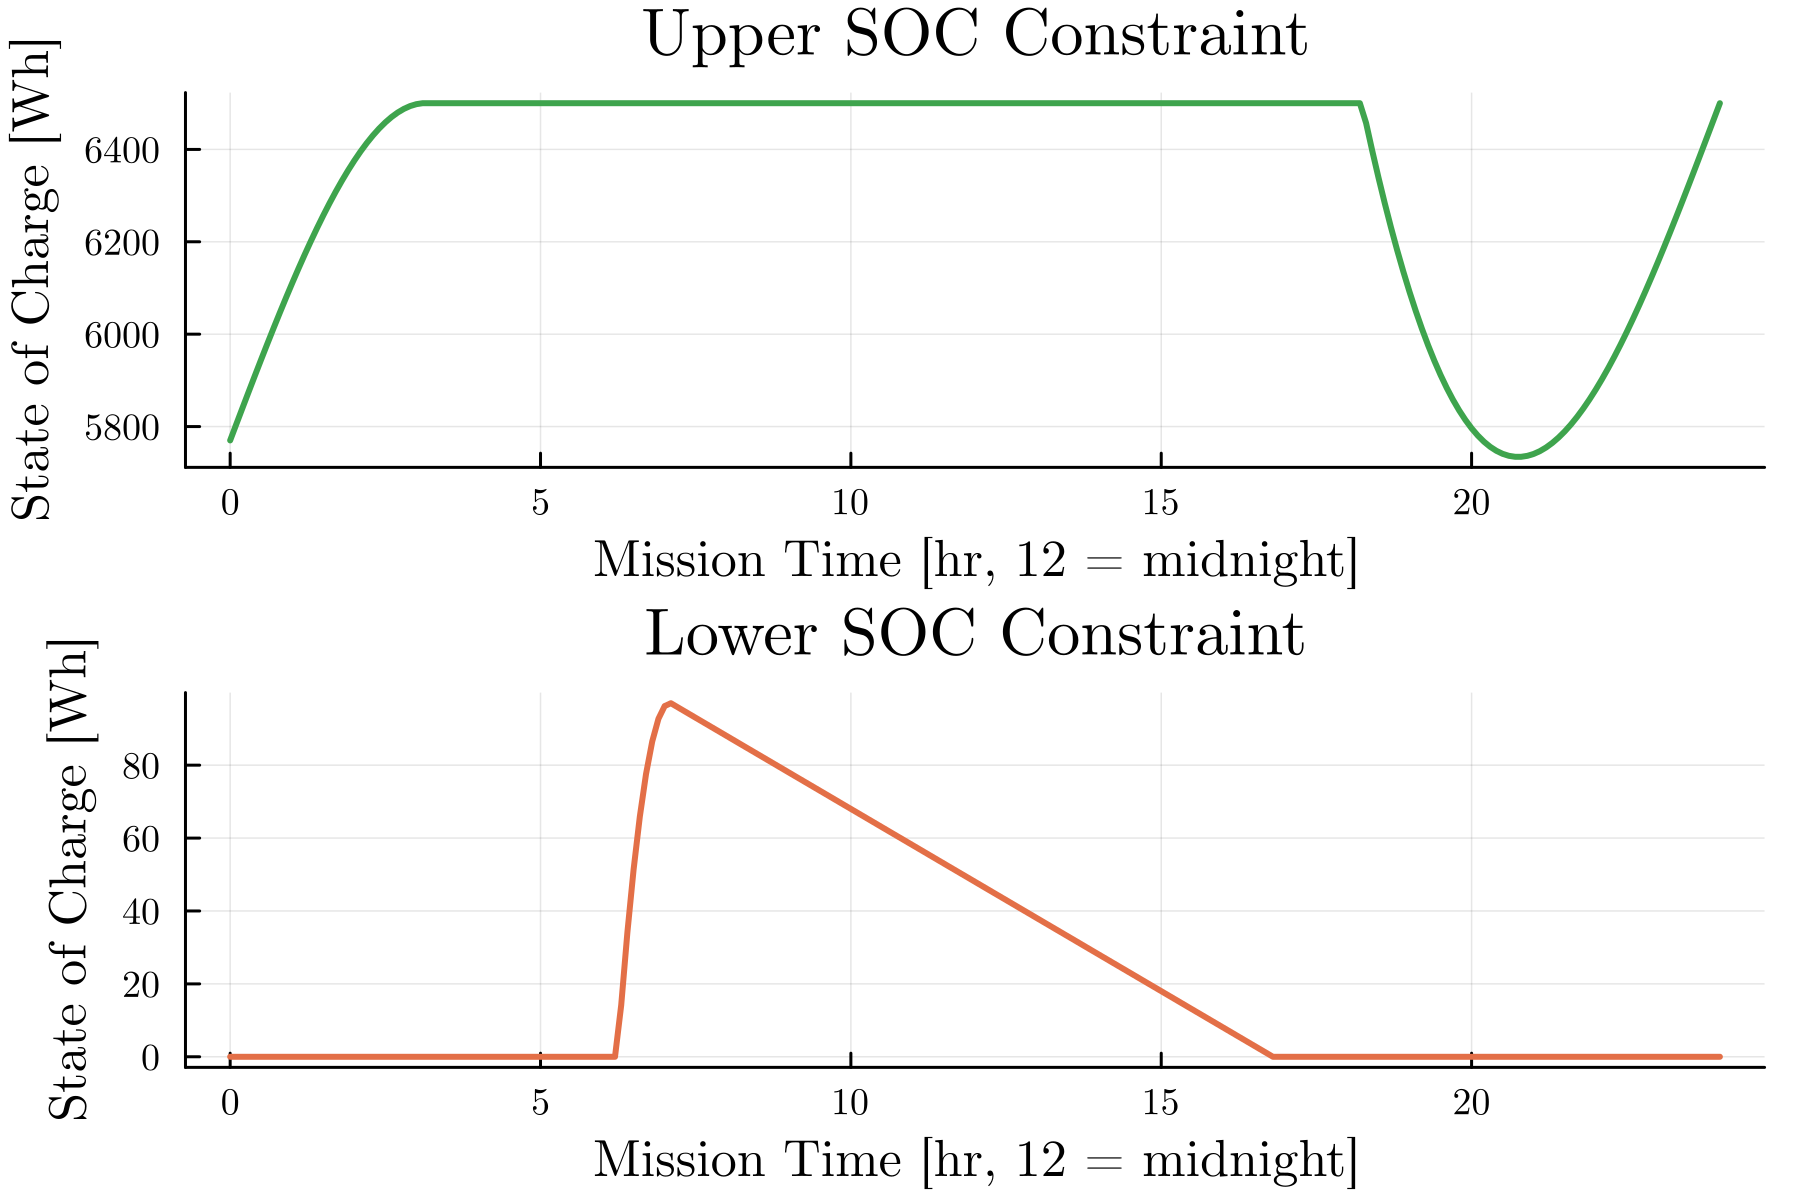
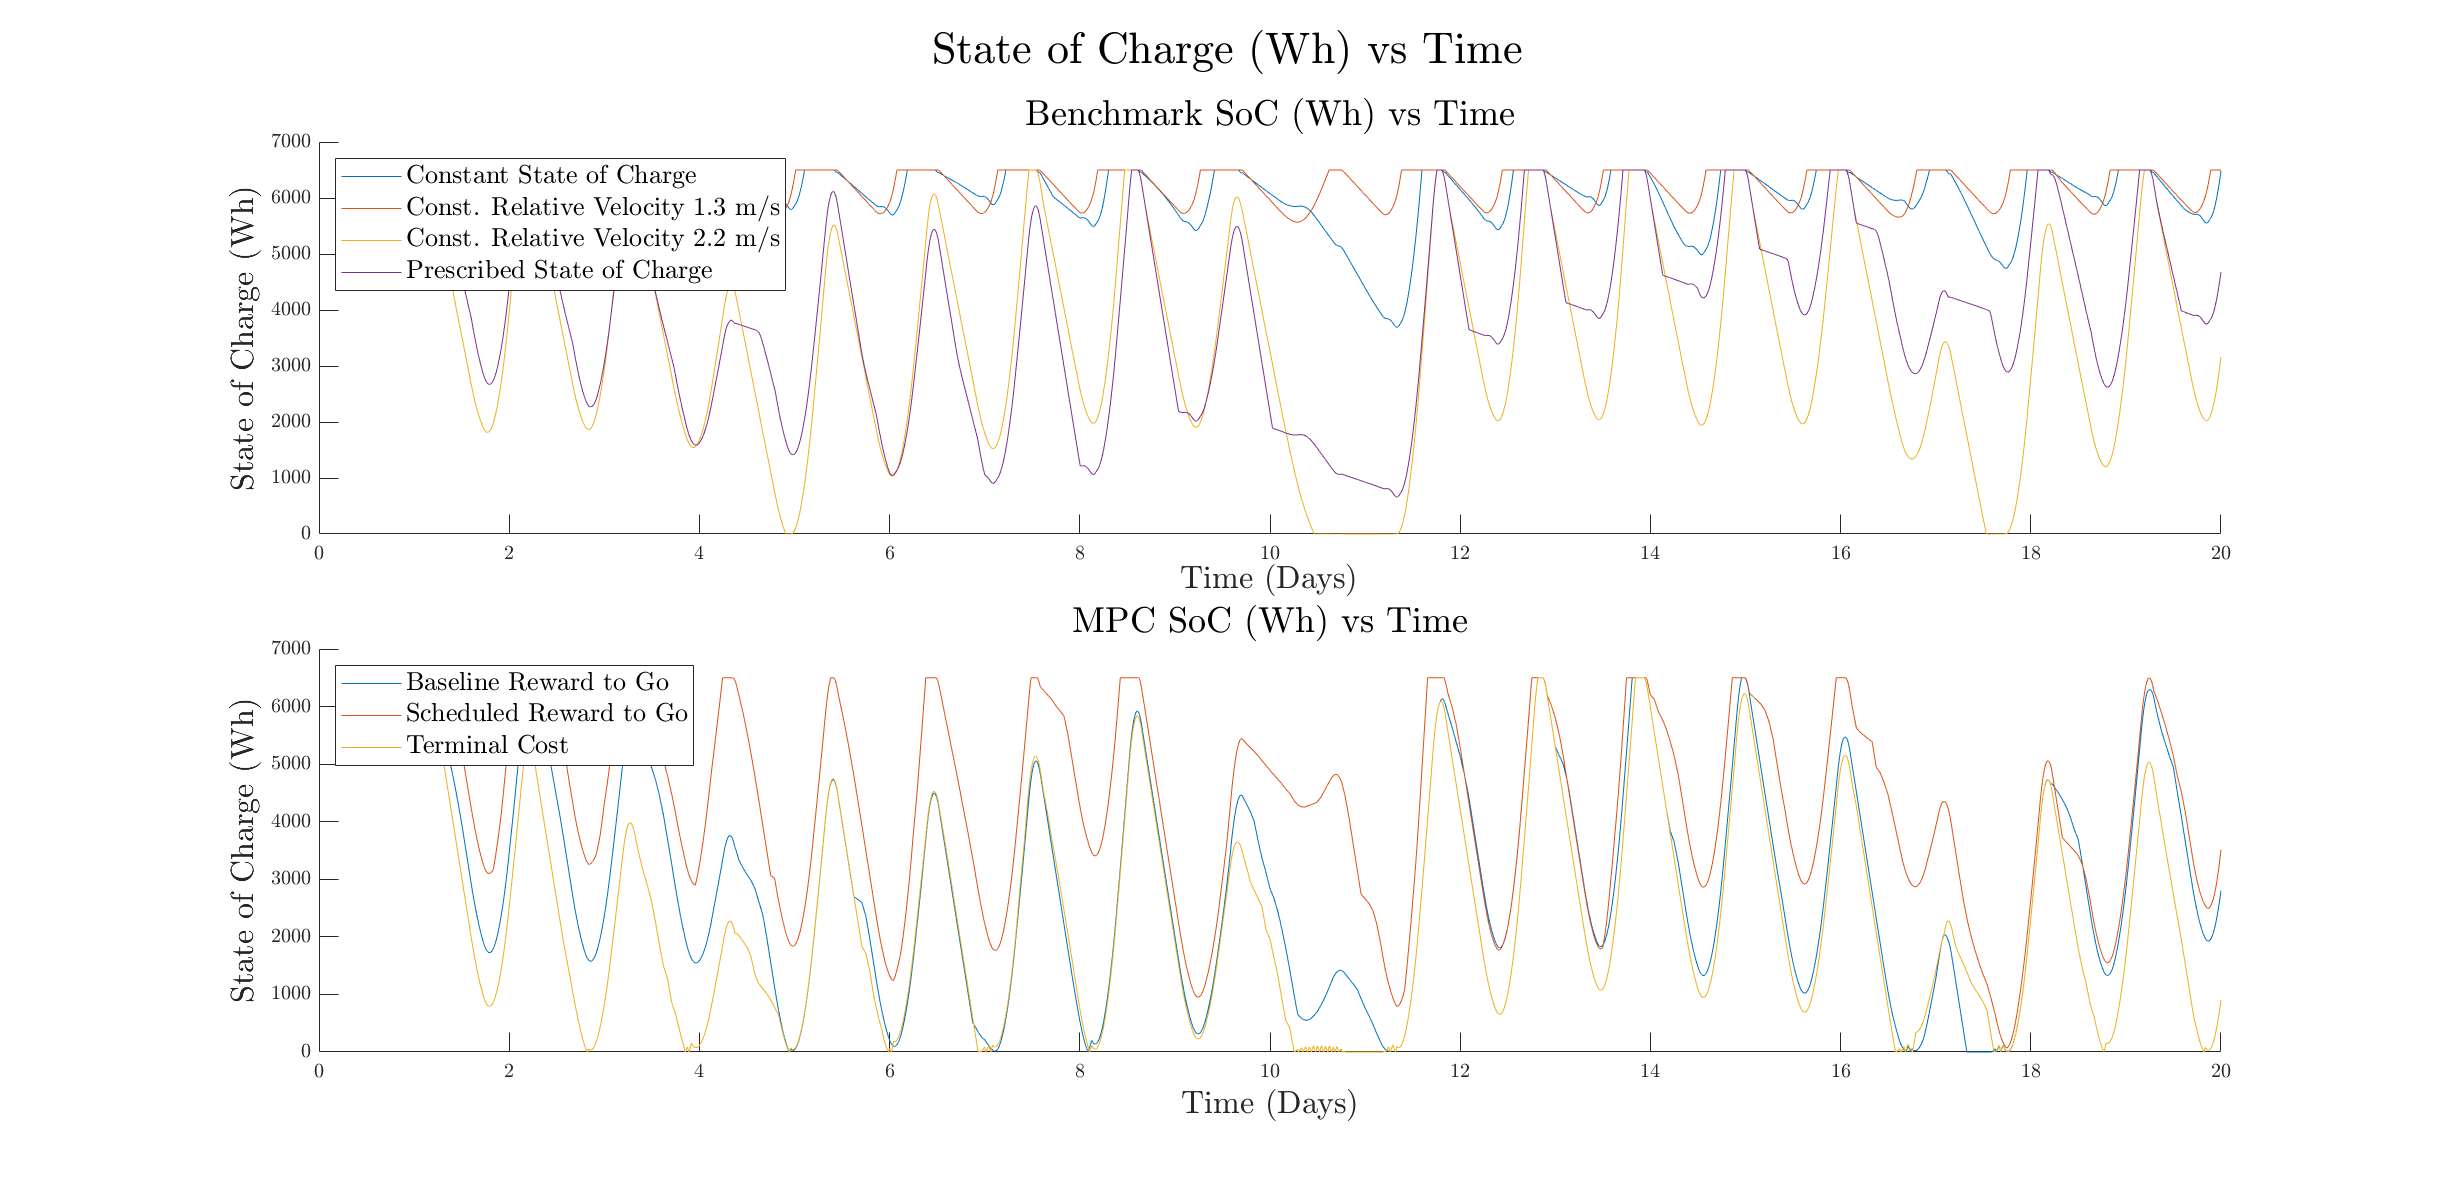
I am a third-year Ph.D. student in Robotics at the University of Michigan. I am an NSF Graduate Research Fellow and am co-advised by Dr. Dimitra Panagou in the DASC Lab and Dr. Chris Vermillion in the CORE Lab. My research focuses on persistent planning and optimal control for renewably-powered robotic vehicles.
I was a Park Scholar at North Carolina State University, where I received a B.S. in Aerospace Engineering and a B.S. in Applied Mathematics. During my time at NCSU, I was involved with Liquid Rocketry Lab where I worked on developing the dynamic model and the guidance, navigation, and control aspects of a spaceshot liquid bipropellant rocket.
In my free time, I enjoy playing the piano and guitar, playing and watching sports, snowboarding, and cooking.
recent updates
-
Dr. Chris Vermillion featured my work on persistent planning and energy-information tradeoffs in his University of Michigan Control Seminar.
-
My work on adaptive mission planning for solar-powered vessels has been accepted to the IEEE Transactions on Control Systems Technology.