cv
Research, engineering experience, education, and service.
Basics
| Name | Kavin M. Govindarajan |
| kmgovind@umich.edu | |
| Phone | +1 (984) 528-0487 |
| Url | https://kmgovind.github.io/ |
| Label | Robotics Ph.D. Student · NSF Graduate Research Fellow |
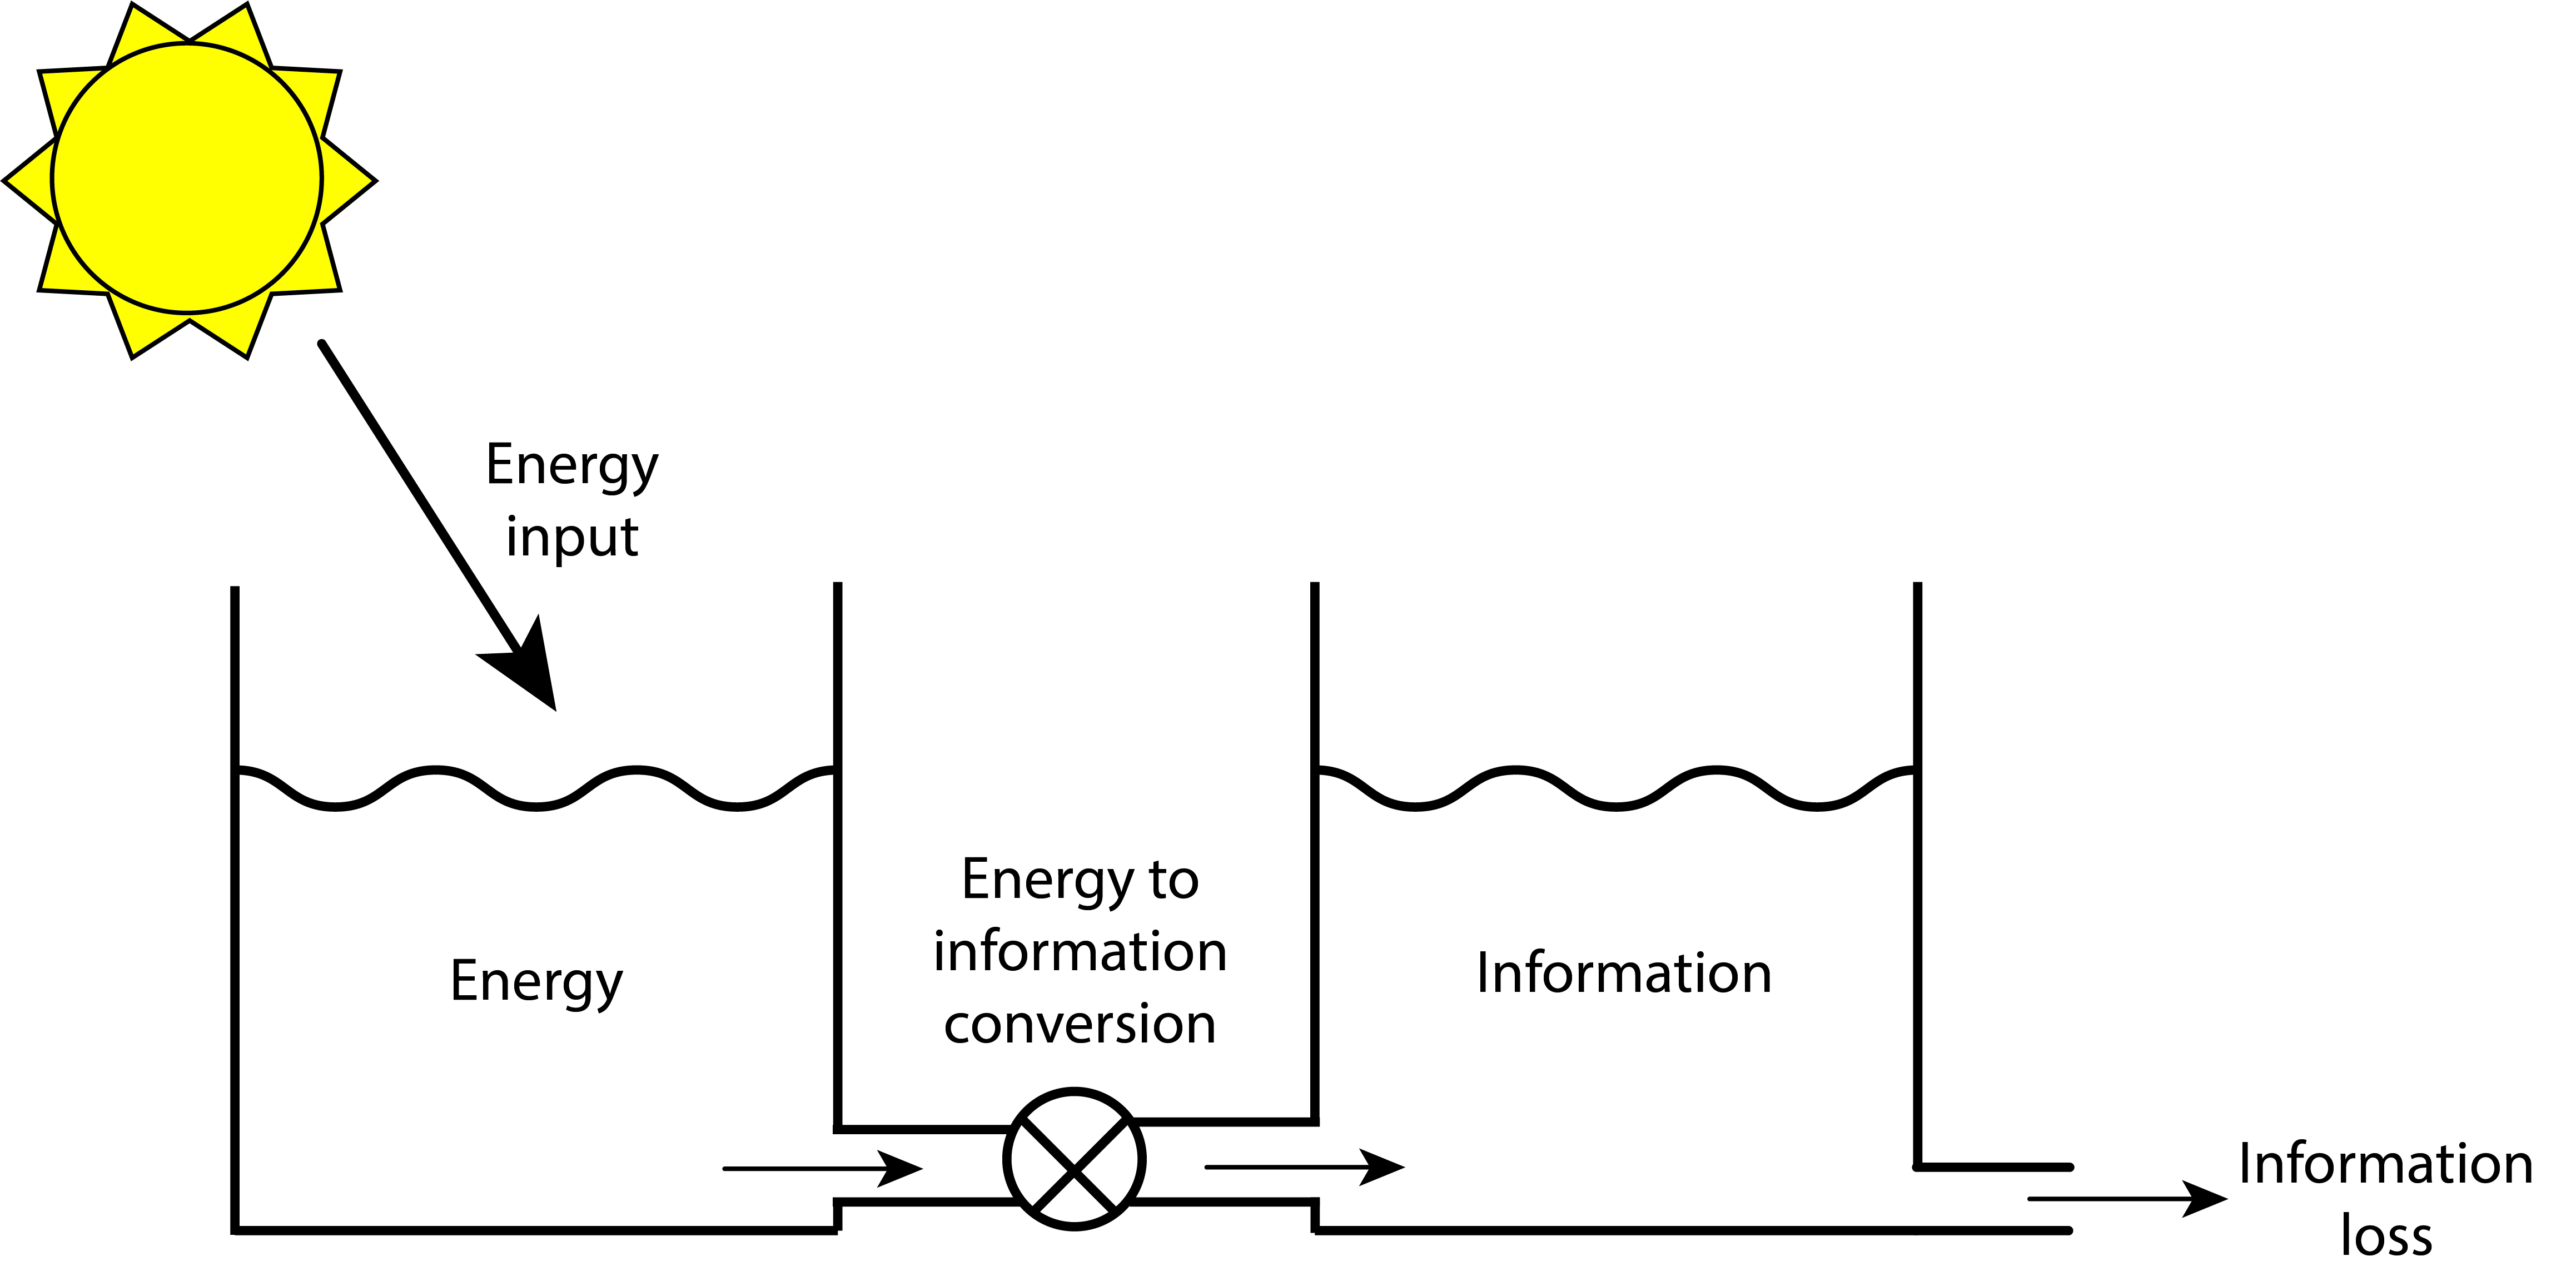
| Summary | I study persistent planning and optimal control for robots that harvest energy from their environment. My research connects energy availability, information gathering, and long-duration autonomy. |
Work
-
2024.08 - Present Doctoral Researcher
University of Michigan · DASC Lab and CORE Lab
Persistent planning and optimal control for sustainably powered robotic systems.
- Co-advised by Dimitra Panagou and Chris Vermillion.
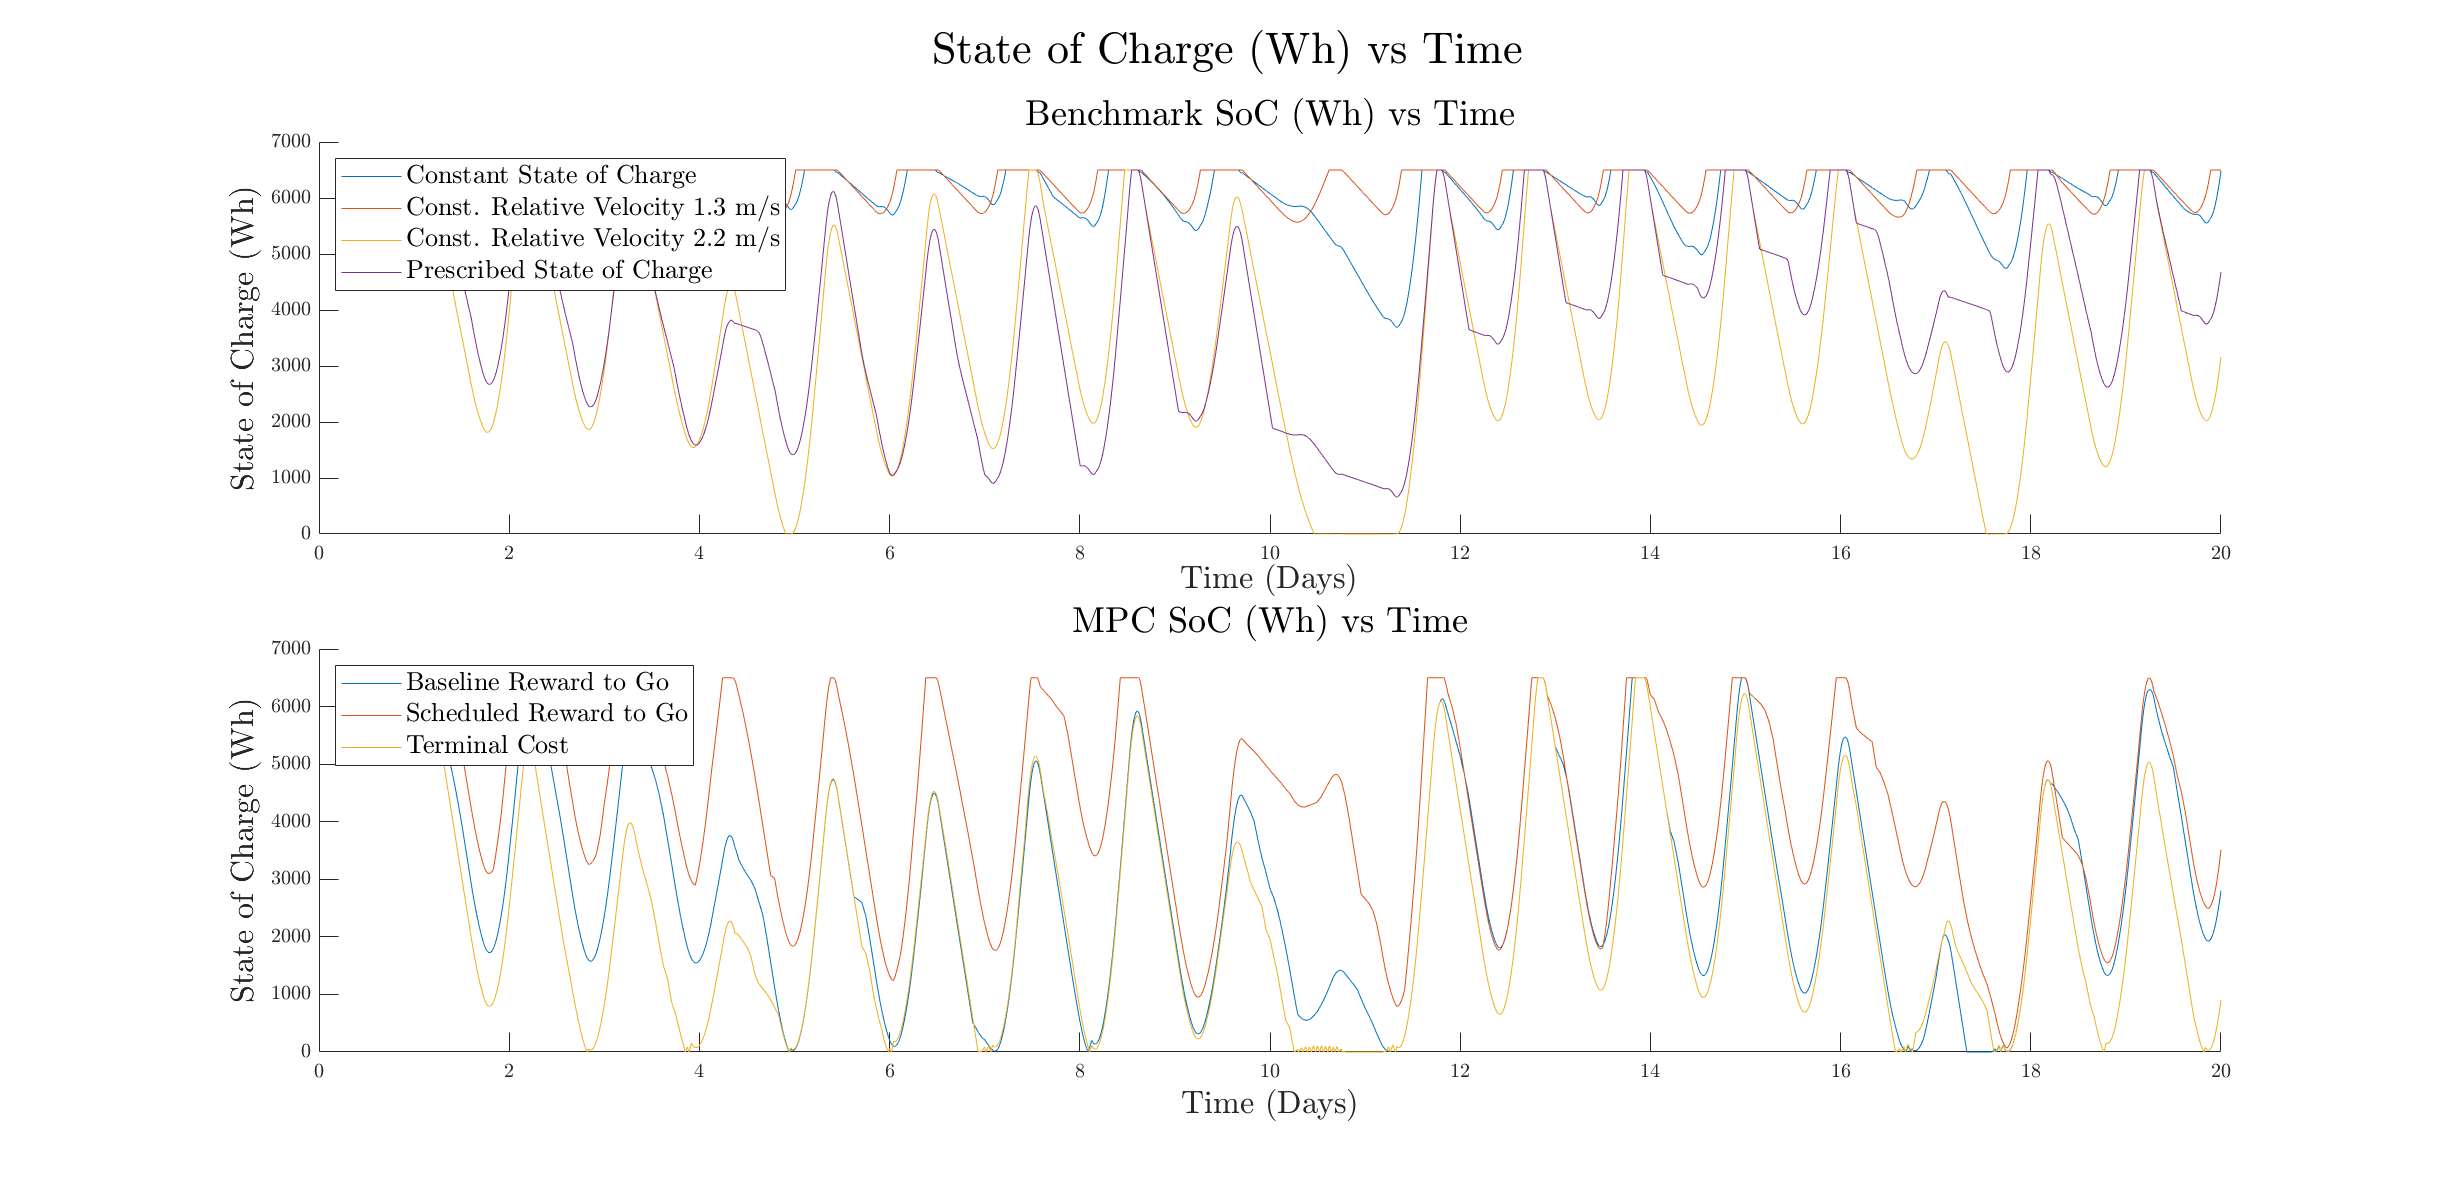
- Study energy-information tradeoffs and periodic speed optimization for persistent environmental monitoring.
- Develop physics-informed neural network methods for learning infinite-horizon value functions.
- Connect information-aware planning with energy constraints for autonomous surface vessels.
-
2020.09 - 2024.05 CFO and Structures Engineer
Liquid Rocketry Lab
Student-led development of a liquid bipropellant rocket.
- Managed financial and legal responsibilities for the organization.
- Developed a dynamic model to support vehicle design and flight control.
- Designed components for the rocket's guidance, navigation, and control system.
-
2019.06 - 2024.08 Undergraduate Research Assistant
CORE Lab
Renewably powered robotics and underwater energy-harvesting systems.
- Developed persistent planning algorithms for renewably powered vehicles in changing environments.
- Conducted field tests of planning and control algorithms on a solar-powered autonomous surface vessel.
- Designed and built composite control surfaces and electronics modules for an autonomous sailing drone.
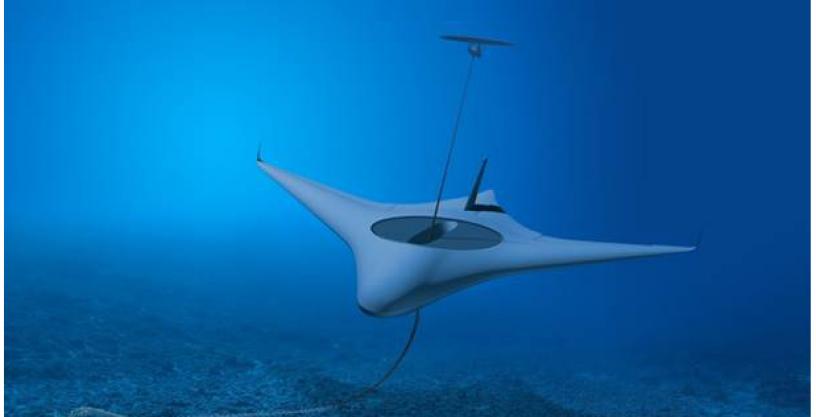
- Developed control software and conducted field tests for an underwater energy-harvesting kite under the DARPA Manta Ray program.
Education
-
2024.08 - Present Ann Arbor, MI
Ph.D.
University of Michigan
Robotics
- Data-Driven Controls
- Autonomous Vehicles
- Probability & Random Processes
- Game Theory
- Multi-Robot Systems
-
2024.08 - 2026.04 Ann Arbor, MI
-
2020.08 - 2024.05 Raleigh, NC
B.S.
North Carolina State University
Aerospace Engineering
- Mechatronics
- Flight Stability & Controls
- Finite Element Analysis
- Rocket Propulsion
-
2020.08 - 2024.05 Raleigh, NC
B.S.
North Carolina State University
Applied Mathematics
- Optimal Control
- Dynamic Systems & Multivariable Controls
- Mathematics of Scientific Computing
Projects
-
Information Value of Energy
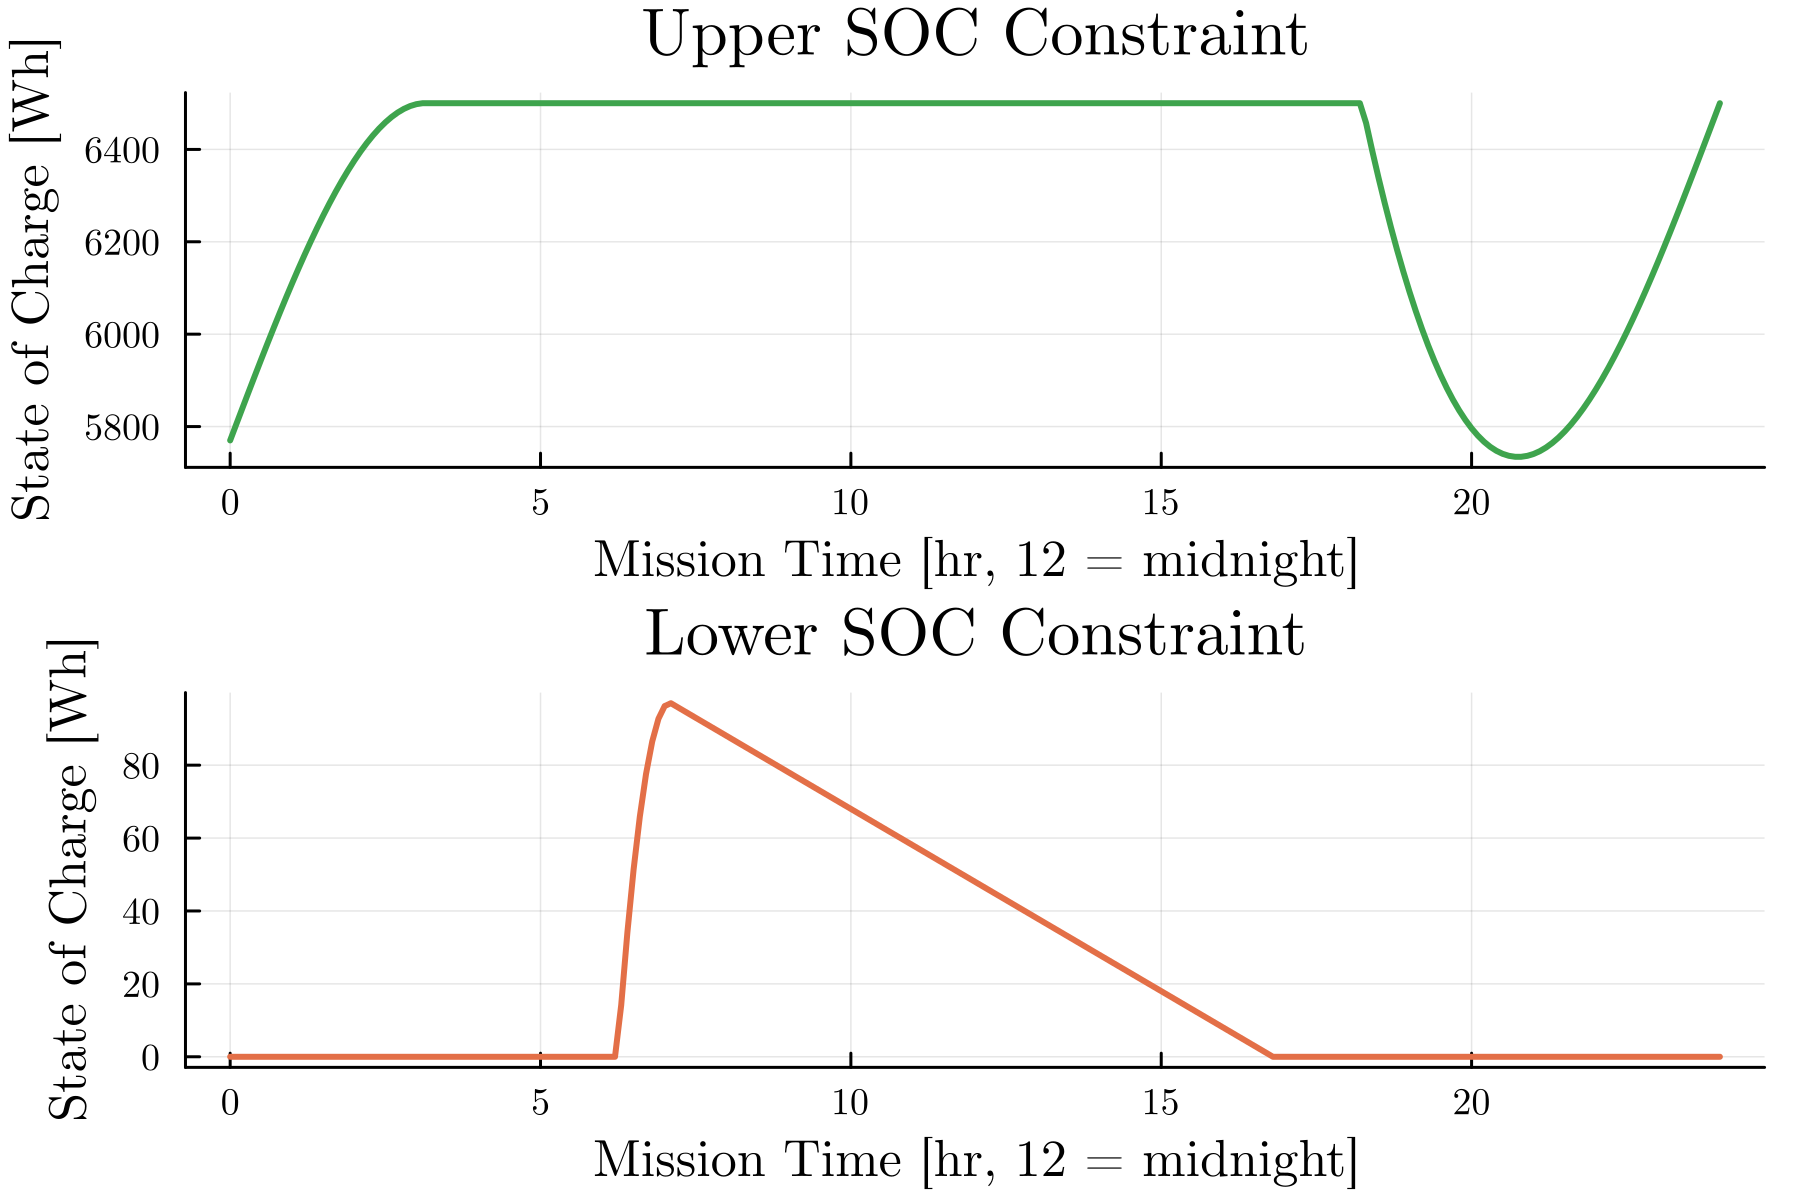
Periodic speed optimization for sustainably powered mobile robots, with a Chesapeake Bay salinity-monitoring simulation.
-
Physics-Informed Neural Networks for Persistent Control
Ongoing work on learned infinite-horizon value functions, with an interactive visualization.
-
Clarity-Driven Adaptive Mission Planning
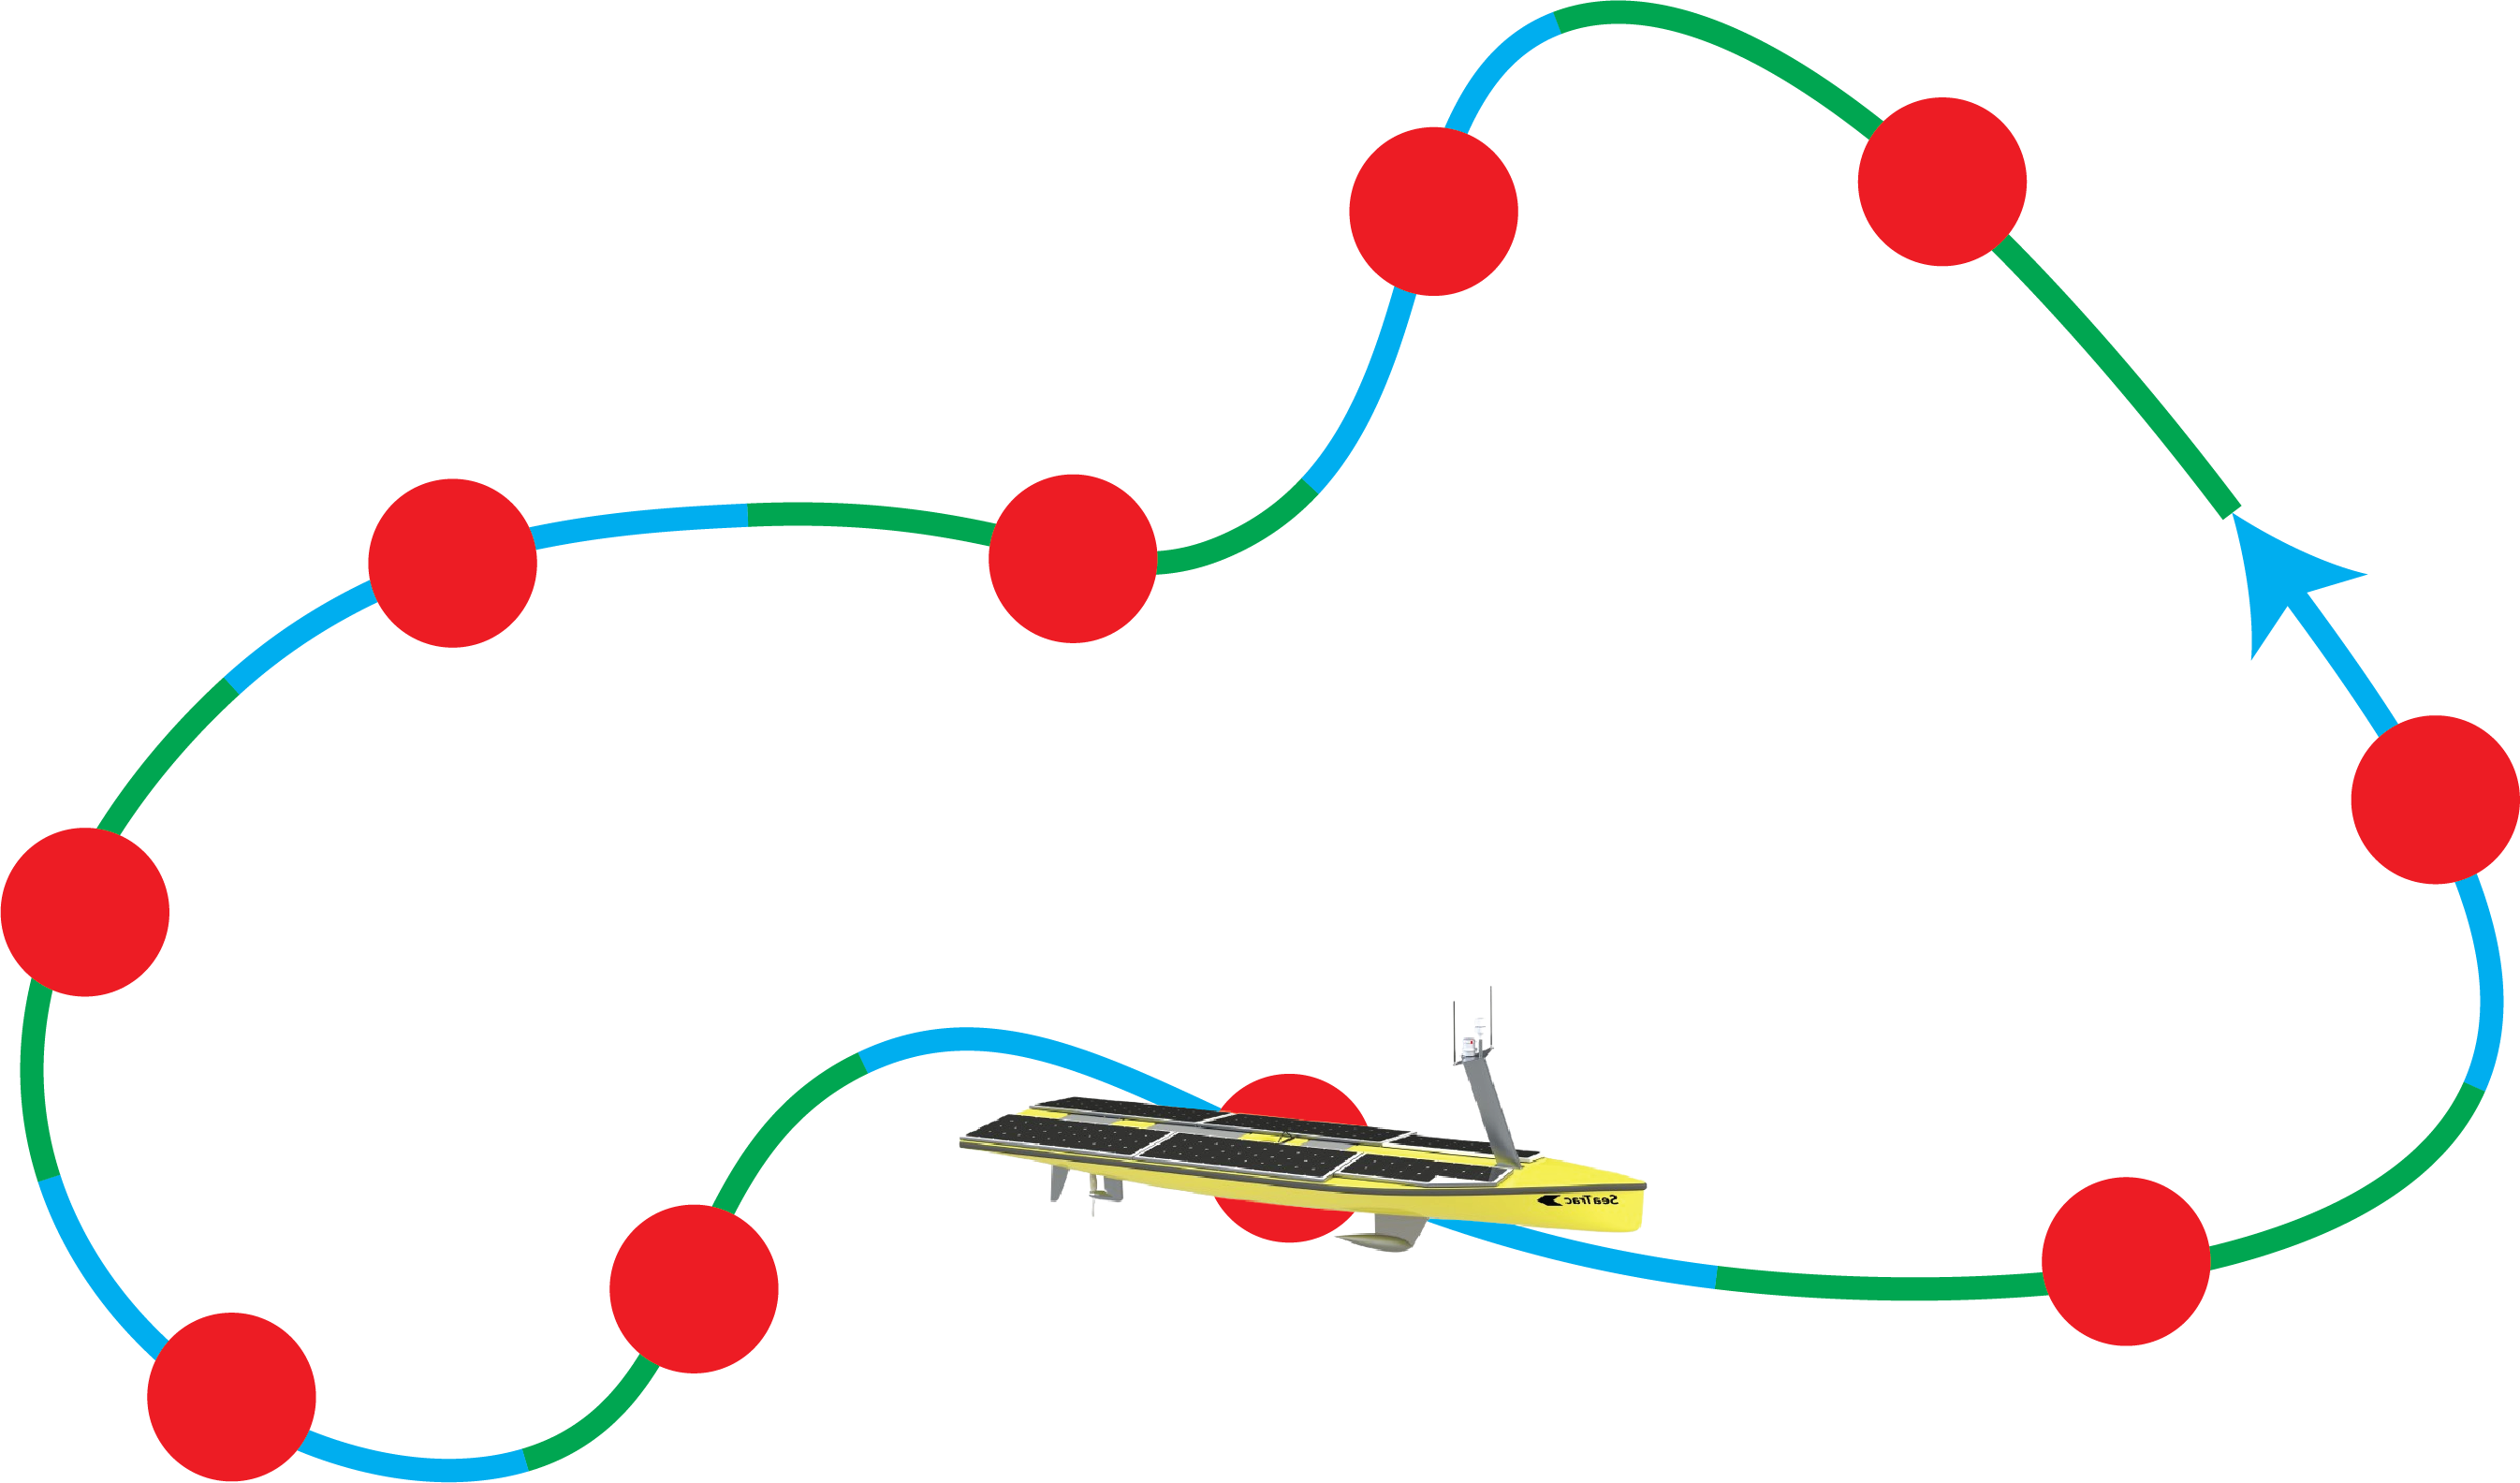
Energy-aware environmental monitoring with simulations and solar-powered vessel field experiments.
-
Coursework Projects
Stochastic safety verification, wave-powered desalination planning, and autonomous sailboat modeling and control.
-
Computer Vision-Aided Robotics
Vision-based target identification, distance estimation, and flywheel control for FRC 6908's Cookie Monster robot.
Volunteer
-
2018.07 - Present Director
InspireNC
Expanding access to STEAM education and community resources.
- Manage nonprofit operations and community impact.
- Organize community events and skills-training workshops.
- Build corporate partnerships to support educational and community programs.
-
Mentor
FIRST Robotics Competition · FRC 6908 Infuzed
Support students in the engineering design process and autonomous robot control.
- Mentor students developing competition robots and higher-level control systems.
- Previously served as the team lead during high school.
Awards
- 2025
2024 ASME Reviewer of the Year
American Society of Mechanical Engineers
Recognized for exceptional contributions to the peer review process.
- 2024
NSF Graduate Research Fellowship
National Science Foundation
Awarded for outstanding research potential in STEM fields.
- 2020
Park Scholarship
North Carolina State University
Four-year scholarship to NC State University awarded for outstanding accomplishments and potential in scholarship, leadership, service, and character.
Skills
| Programming/Software | |
| C | |
| C++ | |
| ROS | |
| MATLAB | |
| Simulink | |
| Java | |
| Python | |
| Julia | |
| Linux (Ubuntu, Raspbian) | |
| Git | |
| JIRA | |
| Confluence | |
| Microsoft Office | |
| LaTeX |
| Computer-Aided Design | |
| SOLIDWORKS | |
| Siemens NX | |
| Autodesk Fusion 360 | |
| Onshape | |
| GrabCAD | |
| ANSYS |
Languages
| English | |
| Native speaker |
| Tamil | |
| Native speaker |
| Spanish | |
| Professional working proficiency |
Interests
| Outside the lab | |
| Piano | |
| Guitar | |
| Sports | |
| Snowboarding | |
| Cooking |
Publications and Manuscripts
2027
-
 [Tentative Title] Physics-Informed Neural Network-Based Persistent Optimal Control of Sustainably Powered Mobile Robots2027(In Preparation)