2027 [Tentative Title] Physics-Informed Neural Network-Based Persistent Optimal Control of Sustainably Powered Mobile Robots Kavin M. Govindarajan, Dimitra Panagou, and Chris Vermillion 2027 (In Preparation) Website Optimally Trading Energy for Information through Speed Trajectory Optimization of Sustainably Powered Mobile Robots Kavin M. Govindarajan, Dimitra Panagou, and Chris Vermillion In American Control Conference (ACC), 2027 (Under Review) arXiv PDF Code Website 2026 Clarity-Driven Adaptive Mission Planning for a Solar-Powered Autonomous Surface Vessel Kavin M. Govindarajan, Kaleb Ben Naveed, David Li, and 5 more authors IEEE Transactions on Control Systems Technology, 2026 (In Press) arXiv PDF Code Website 2025 Clarity-Driven Ergodic Control for Persistent Tip-and-Cue Missions with Synchronized Rendezvous David Li, Kavin M. Govindarajan, and Chris Vermillion In 2025 IEEE 64th Conference on Decision and Control (CDC), 2025 DOI PDF Code Slides Fusion of Indirect Methods and Iterative Learning for Persistent Velocity Trajectory Optimization of a Sustainably Powered Autonomous Surface Vessel Kavin M. Govindarajan, Devansh R. Agrawal, Dimitra Panagou, and 1 more author In 2025 IEEE Conference on Control Technology and Applications (CCTA), 2025 DOI arXiv PDF Code Slides Analysis and Experimental Validation of a Low-Complexity Enhanced Orientation-Based Controller for Tethered Energy-Harvesting Systems Jacob B. Fine, Peter Newell, Kavin Govindarajan, and 8 more authors IEEE Transactions on Control Systems Technology, 2025 DOI PDF 2023 Predictive Velocity Trajectory Control for a Persistently Operating Solar-Powered Autonomous Surface Vessel Kavin Govindarajan, Ben Haydon, and Chris Vermillion In 2023 American Control Conference (ACC), 2023 DOI PDF Slides 2022 Coverage-Maximizing Solar-Powered Autonomous Surface Vehicle Control for Persistent Gulf Stream Observation Kavin Govindarajan, Ben Haydon, Kirti Mishra, and 1 more author In 2022 American Control Conference (ACC), 2022 DOI PDF Code Slides
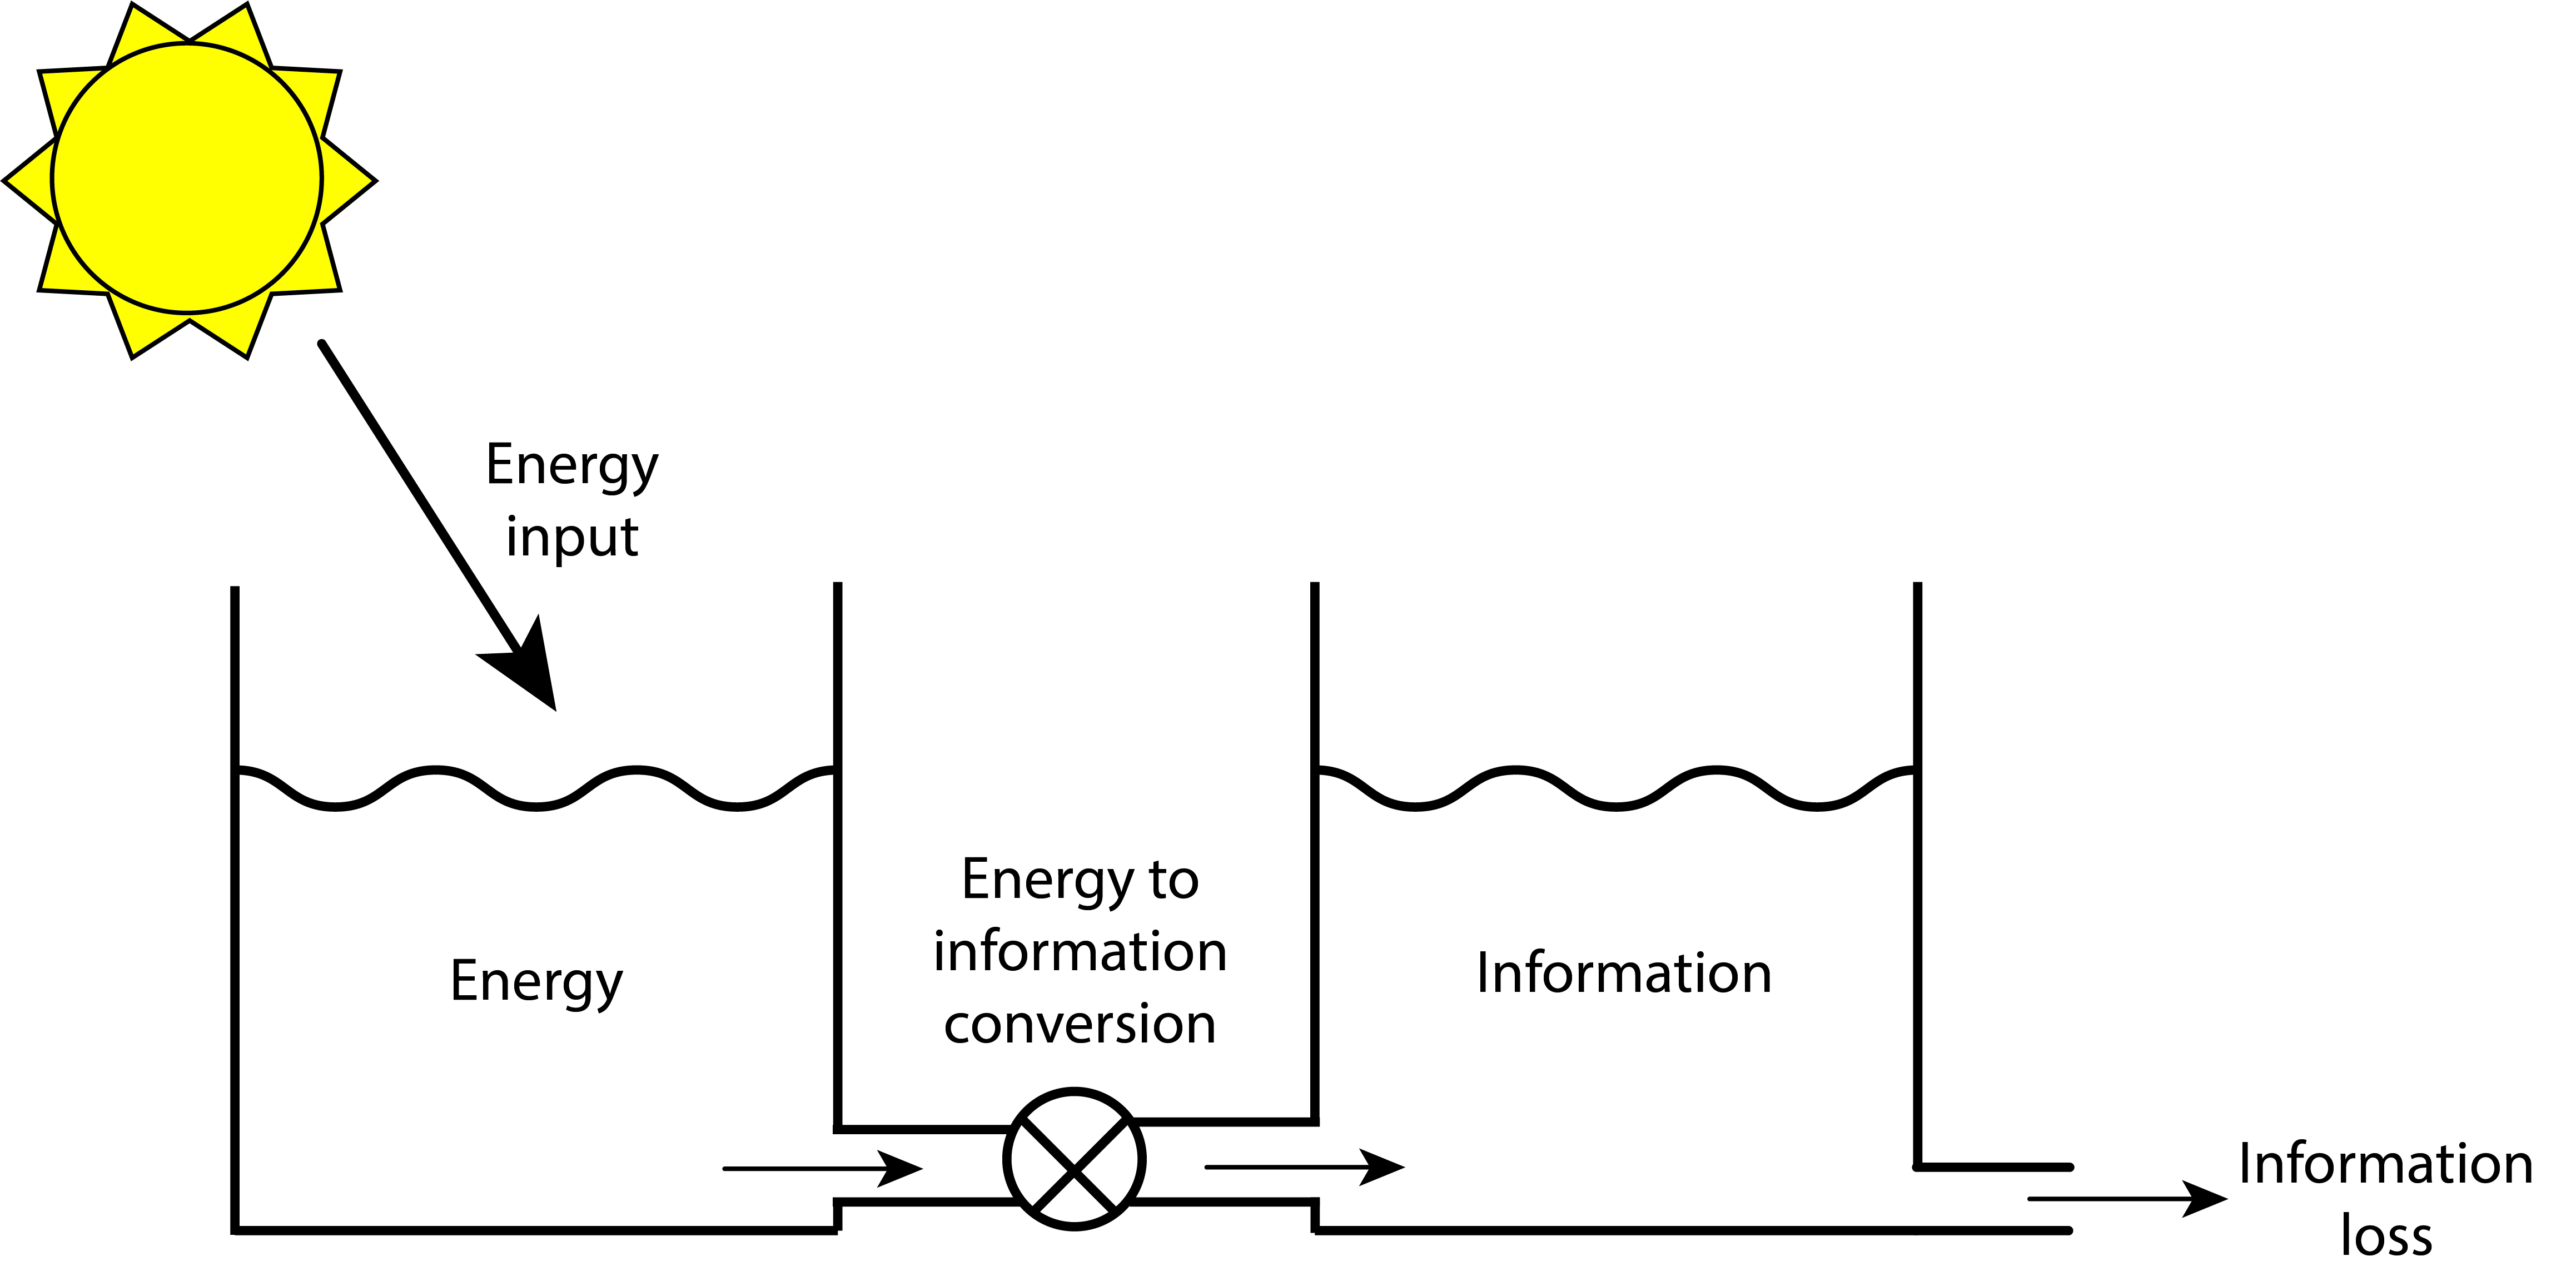 [Tentative Title] Physics-Informed Neural Network-Based Persistent Optimal Control of Sustainably Powered Mobile Robots2027(In Preparation)